A robot arm with a gripper that repeatedly picks and places a cube, designed model-based from scratch.
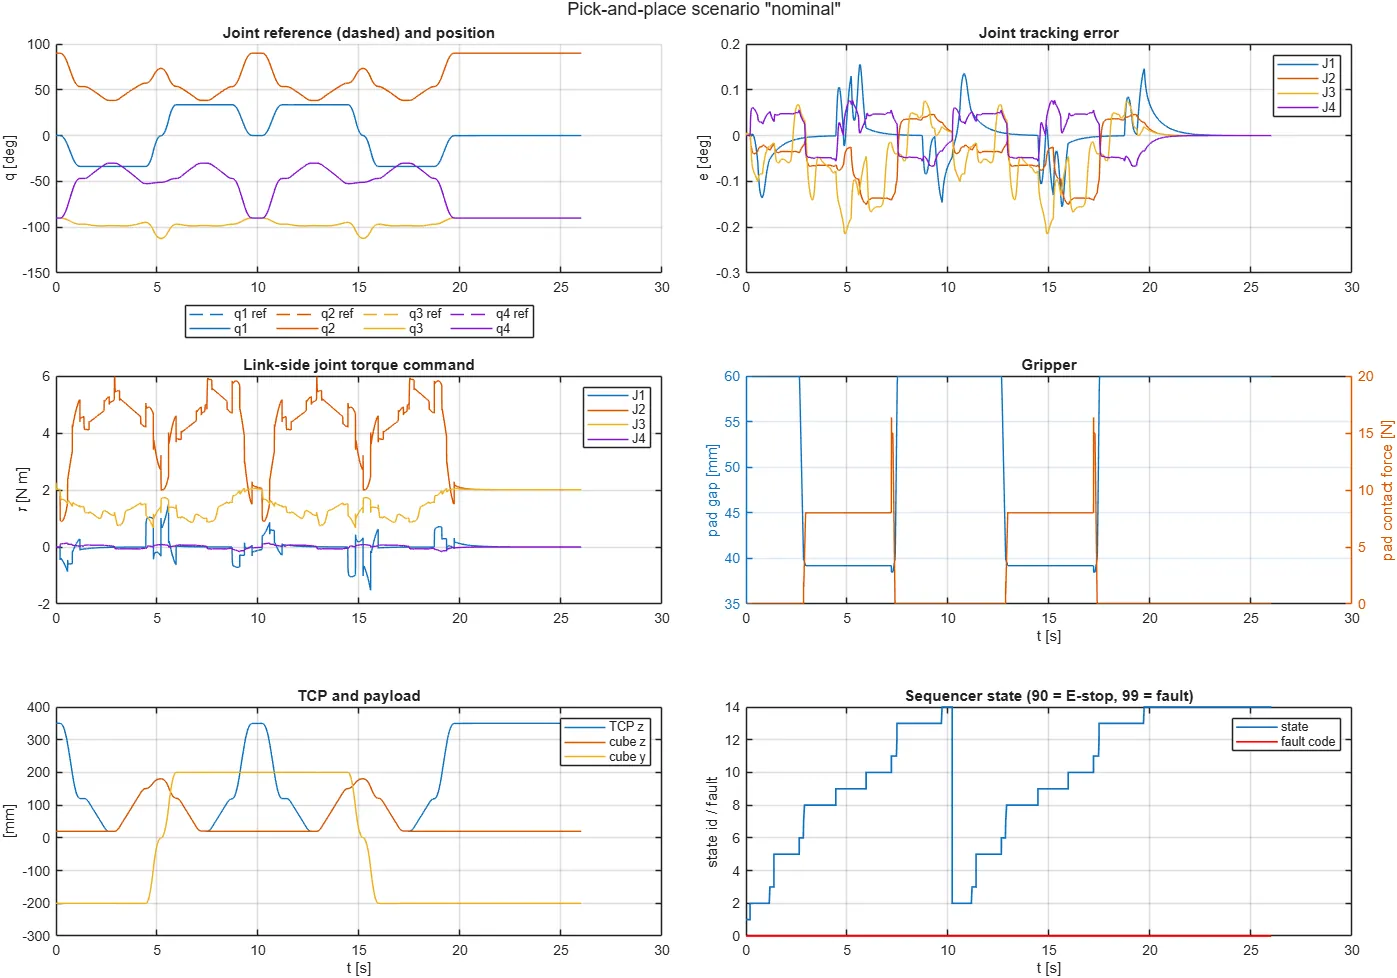
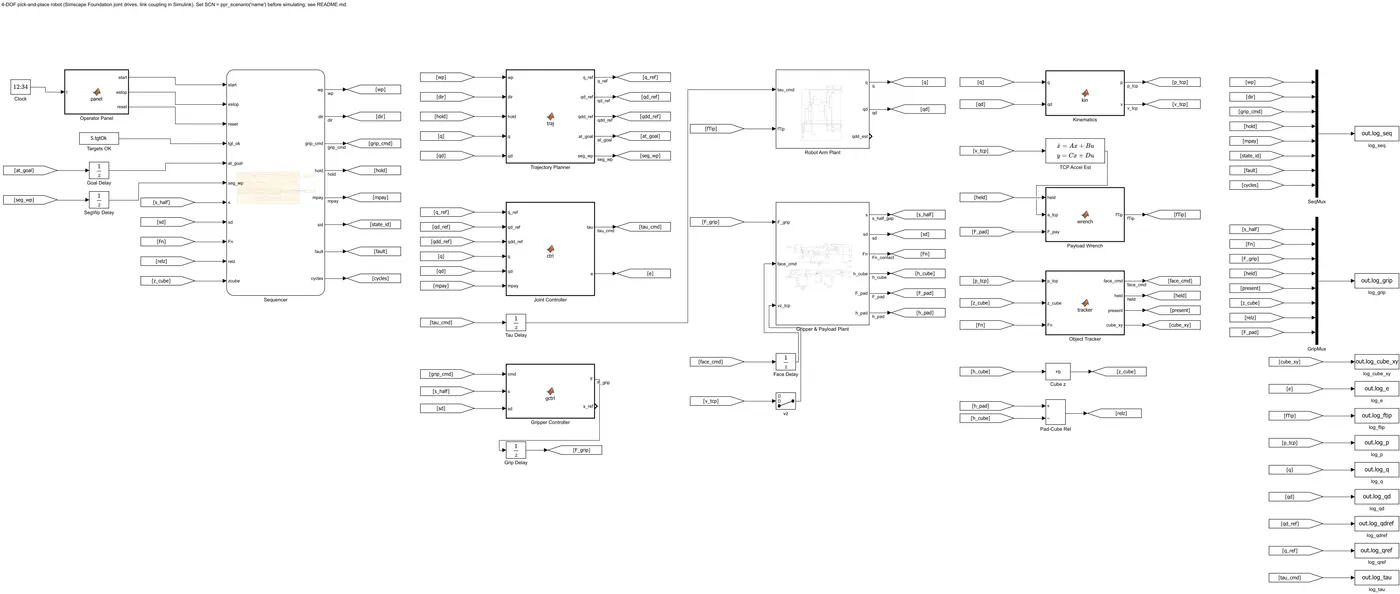
Build a 4-DOF arm with kinematics, inverse kinematics, trajectory planning, joint drives and a Stateflow sequencer, and test normal and fault scenarios.
Join a live course and build models like this step by step.
Call / WhatsApp +91 80155 06307 · director@auravolt.in